

Boston Dynamics engineers taped their ring fingers to their little fingers and went about a day of ordinary tasks. After that experiment the team decided that Atlas's new hand would get no pinky. On Thursday 1 October the company showed the result: four fingers, 13 degrees of freedom instead of the previous seven, and a thumb that lets the robot manipulate an object in its hand, turn it, regrip after a slip and hold a tool with a finger on the trigger. In an industry where most companies copy the human hand, it is a decision against the grain.
What was actually shown
The new hand carries the designation GR3 in the company's materials and replaces the seven-degree GR2. The thumb has four degrees of freedom and the other three fingers three each, with the ability to splay, which makes 13 in total. A single type of actuator drives every joint, with no fragile cables crossing the joints, and dense pressure sensors cover the fingertips and the palm. The hand is about the size of a large human hand, because actuator size forces the scale, and it keeps the strength of the previous one: the company gives the example of Atlas carrying a loaded mini-fridge weighing more than 100 pounds, about 45 kg. That is the robot's payload, not a separate specification for one hand.
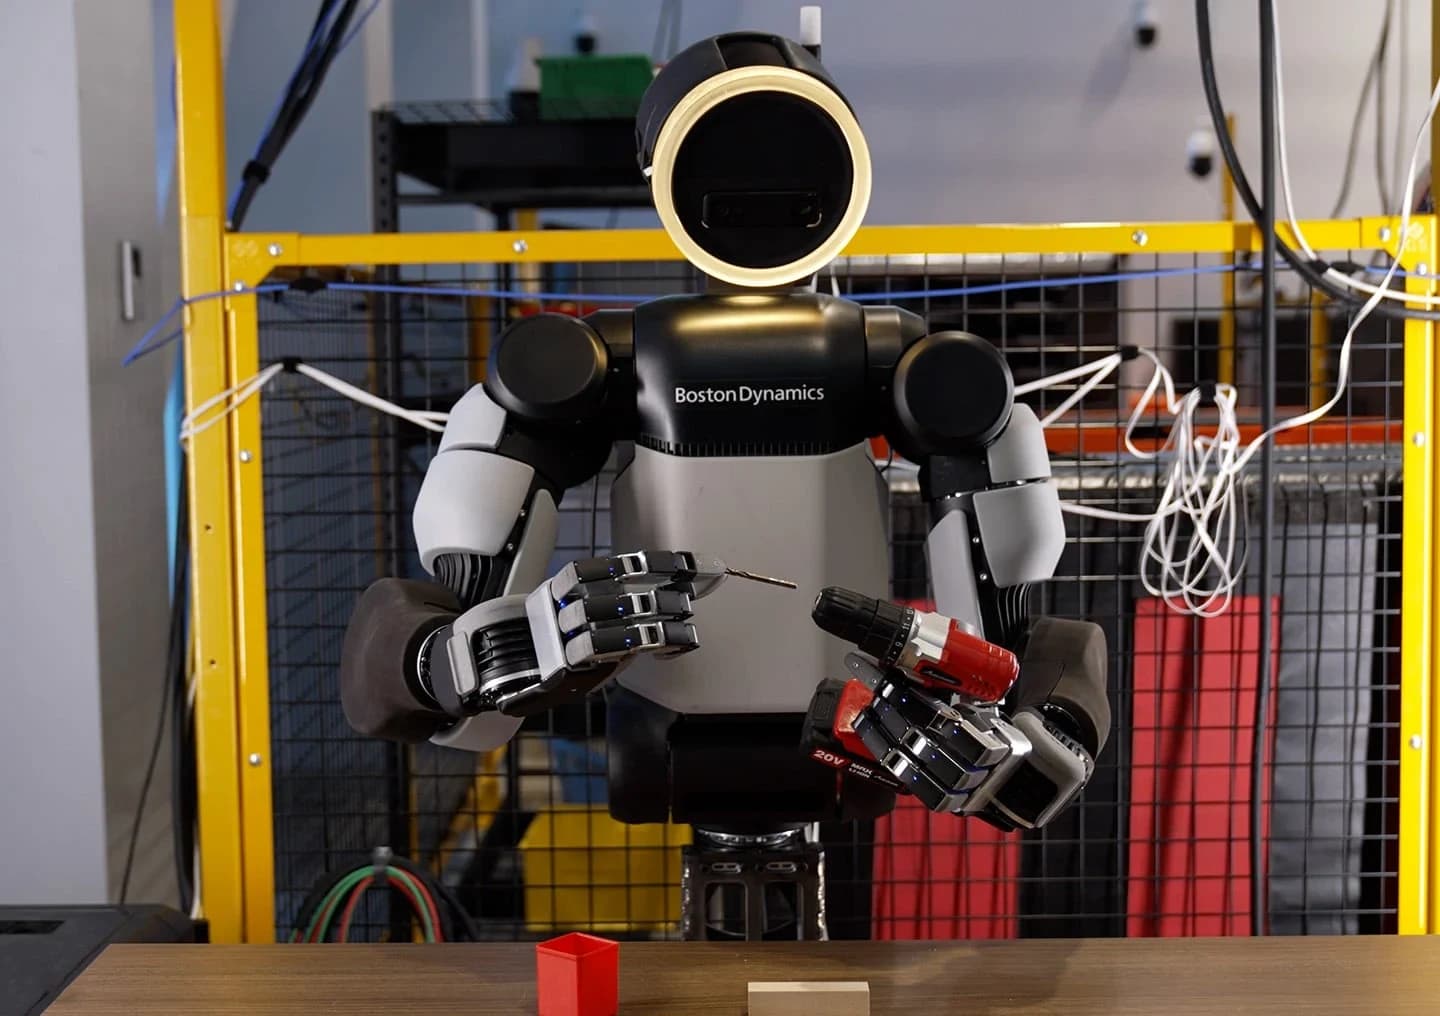
The press photo shows Atlas with a cordless drill in one hand and a drill bit in the other. The company lists drills and powered torque drivers as examples of tools the robot is meant to hold and operate.
The company describes what the layout is for with three examples: turning an object in the hand without putting it down, recovering a grip when a part starts to slip, and holding a tool while pressing its trigger. The thumb moves along and across the fingers, which allows different pinches, three-point grasps and tool grips. Researcher Trevor Ablett described the hand in the video as a "whole mini-robot", given the number of joints and motors that fit in one hand. Boston Dynamics calls the new hand a companion to the new generation of Atlas, a robot with a payload of more than 100 pounds and a design simple enough for mass manufacturing.
Why no pinky
The reasoning is a cost calculation. A fifth finger means three more actuators, plus wiring, control and structural volume, and every extra element is cost and one more place to fail in work meant to run for years on a factory floor. Chief Product and Technology Officer Zack Jackowski asked the team to tape their ring and little fingers together for a day and report what they could not do. At the end, the company wrote, there was agreement: no pinky.
Set that against the assumption of most humanoids, that since the world is built for the human hand, the robot should get a hand as close to it as possible, which also gives access to a huge store of human demonstration recordings. Boston Dynamics grants that logic in its post, then writes that hand design is a ruthless trade-off between dexterity, strength, ruggedness, cost, repairability and sensing. With four fingers the company is betting that the last finger is not worth its cost.
Learn in simulation
The second half of the post matters more for the robot's future than the finger count. The team designed the hand so it can be simulated faithfully, because reinforcement learning in simulation is meant to be the main way of training dexterous behaviour. The company's argument is that human recordings capture the visual context of a task well, but fast, agile manipulation is a product of closed-loop control and force regulation, and wearable devices worn by people do not record the action signals needed to drive such a hand. Backdrivable joints are meant to cope with impacts more easily because they yield under external force, and simpler physics makes them easier to model. Training varies friction, motor parameters and object shapes before policies move to real hardware. That is an engineering rationale, not a published durability test.
Here are the limits of what the company showed. According to Humanoids Daily, Boston Dynamics reports promising early results transferring policies to hardware but gives no broad task-success benchmark, and part of the footage in the video is labelled teleoperated. Other reports describe tasks done autonomously, such as shifting two golf balls in one hand. The hand can do what was shown, but nobody knows yet how often it succeeds.
Where it will end up
The production Atlas debuted at CES 2026, and the first units go to Hyundai Motor Group and to Google DeepMind. Hyundai plans 25 thousand Atlas robots across Hyundai and Kia plants, with the Metaplant in Georgia due to start in 2028 and the Kia plant a year later. On 21 September Boston Dynamics opened the Robotics Metaplant Application Center near Savannah, where Atlas learns real tasks, starting with parts logistics, sorting and sequencing. A hand raised from seven to 13 degrees of freedom makes sense there, because moving a part, adjusting a grip and operating a tool are different jobs from simply holding.
The same Google DeepMind that gets some of the first Atlases is developing its own robotics model, which we covered with Gemini Robotics 2 and the Apollo 2 robot, and has just announced Gemini 4 Argon.
Dropping the pinky is, in our view, the most convincing design decision in this industry in a long time, because it rests on a test and not on looks. A humanoid is meant to work in a factory, not impersonate a person at a trade show, and a hand with fewer parts that can fail is a better answer than a faithful copy of the human one. The company's post also openly describes its compromises, which makes judging it easier.
The strongest objection concerns evidence. There is no broad success test, part of the video is teleoperated work, and the distance from a lab to a hall where a hand must press tool triggers eight hours a day is long. A 13-degree hand trained in simulation is a bet that transferring results from simulation to hardware works at scale, and the company has not proven that yet.
Nobody has published a set of tasks on which the hands of different humanoids could be compared, so comparisons with competitors stay at the level of impressions from video. The real result will come in 2028, when Atlas starts sequencing parts in Georgia, and we will return then to the question of whether the missing pinky bothered anybody there.
Comments
Discussion
Join the conversation around this story.
Join the discussion
Sign in to comment and reply to other readers.
Sign inNo comments yet
Start the discussion first.